Robot Control & Safety
Robust and safety-aware control for reliable physical interaction.
All research areas
Robust Control · Safe Interaction · Adaptation
Robust and safety-aware control methods that enable reliable physical interaction under uncertainty, disturbances, and dynamic environments.
Research Topic
Ongoing research platforms and integrated systems.
Research Topic
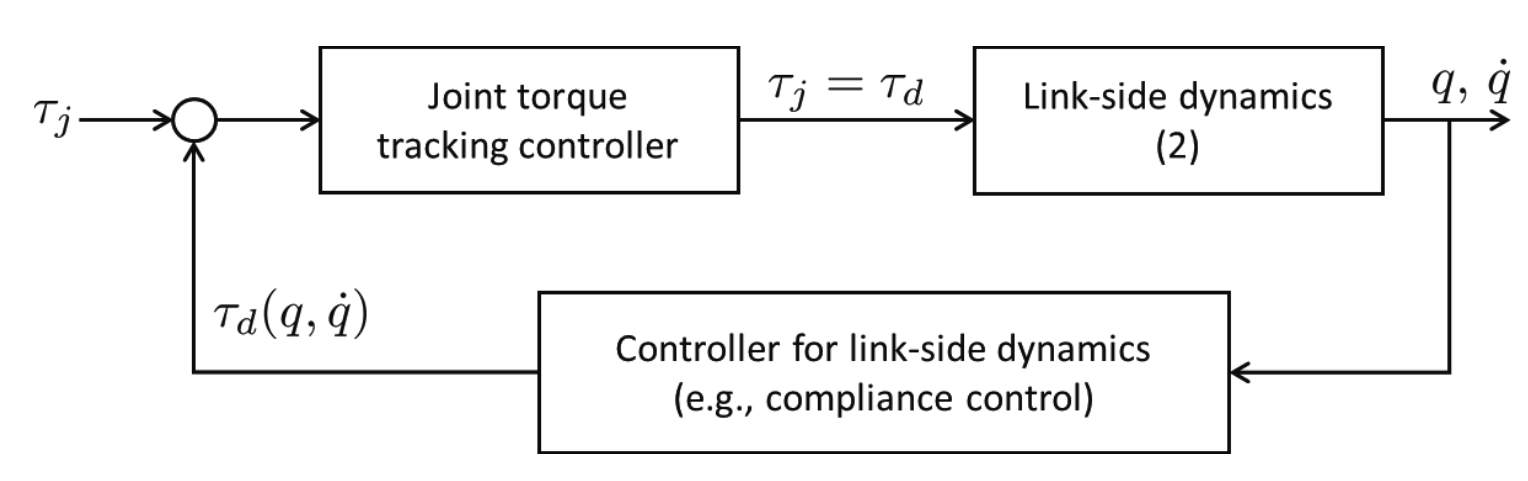
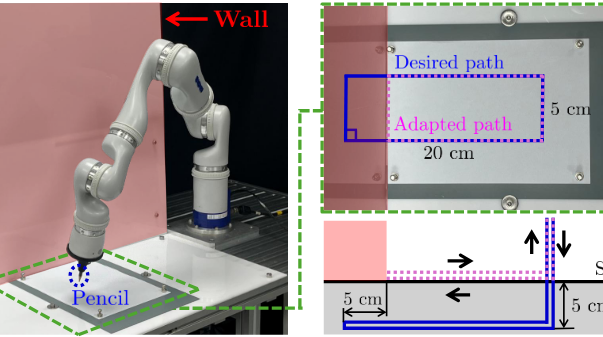
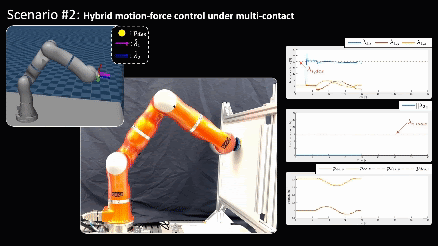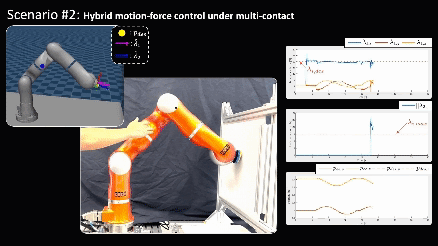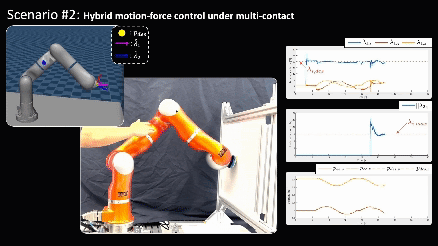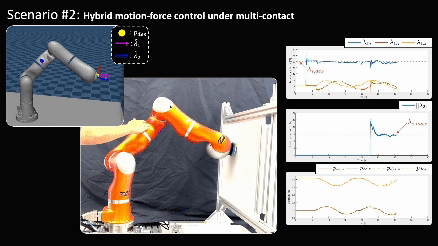
Physical Interaction Control
Control principles for autonomous physical interaction in uncertain, unstructured, and contact-rich environments.
View Research Topic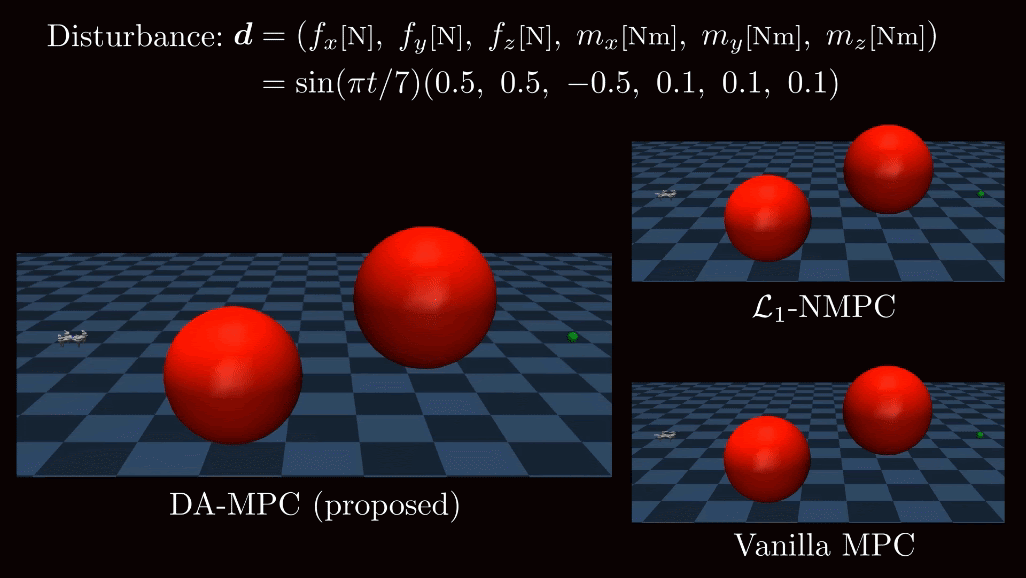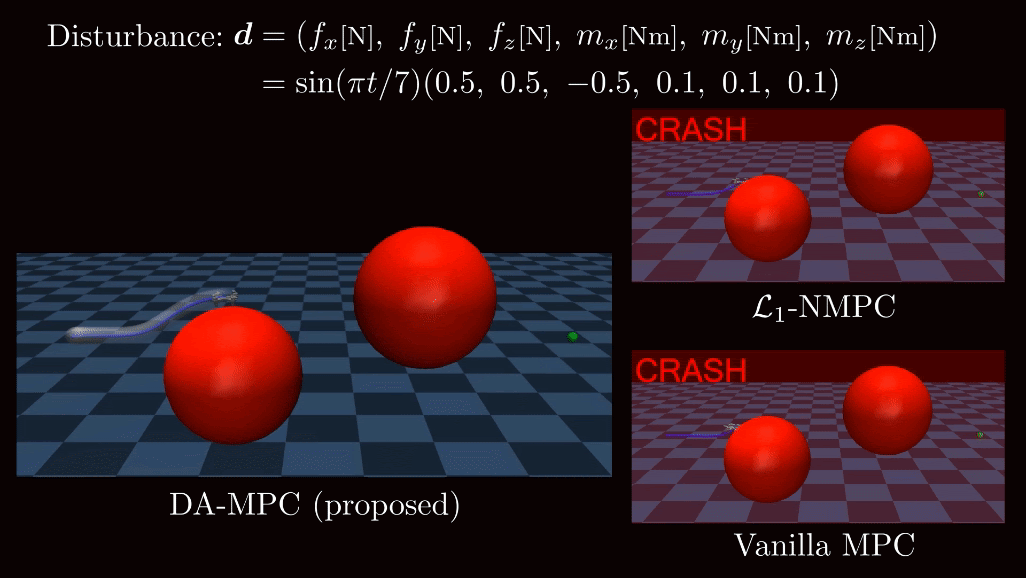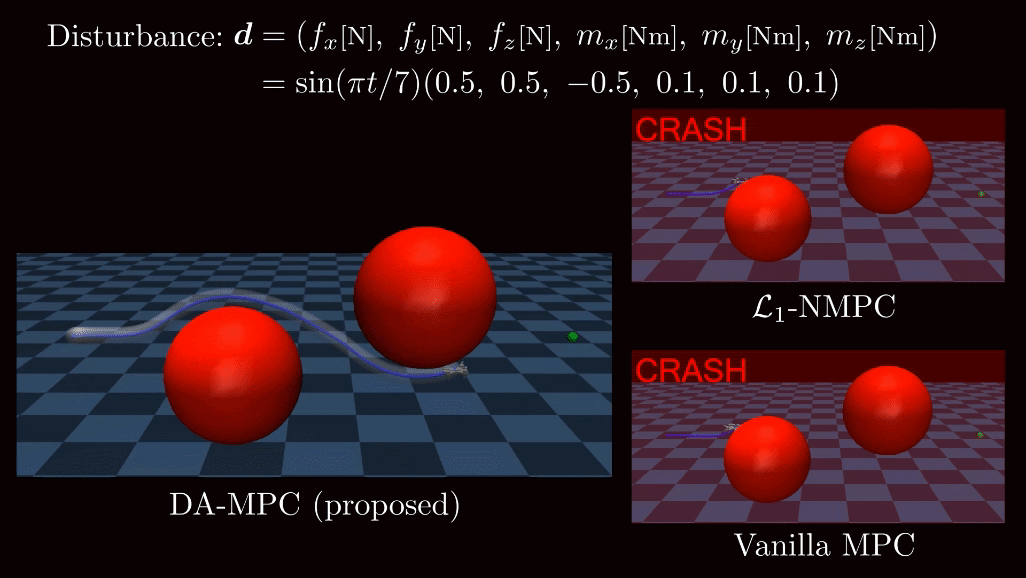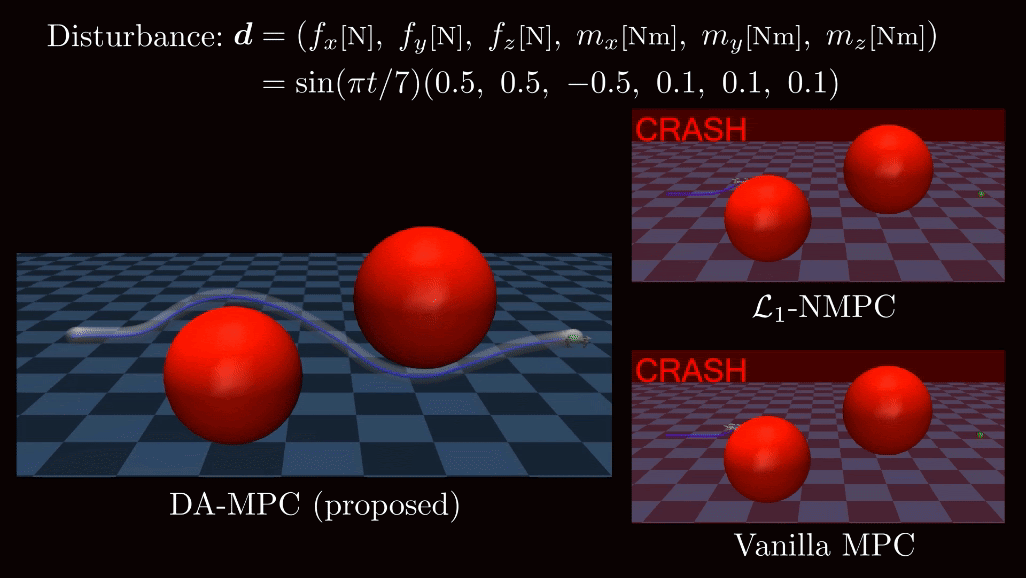
Research Topic
Constraint-Aware Control
Control methods that remain robust to uncertainty while respecting the constraints required for safe and dependable real-world operation.
View Research TopicPublications
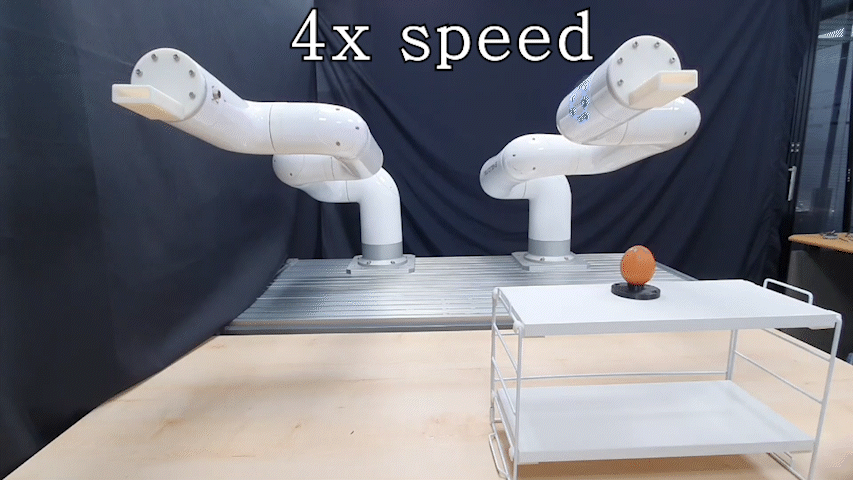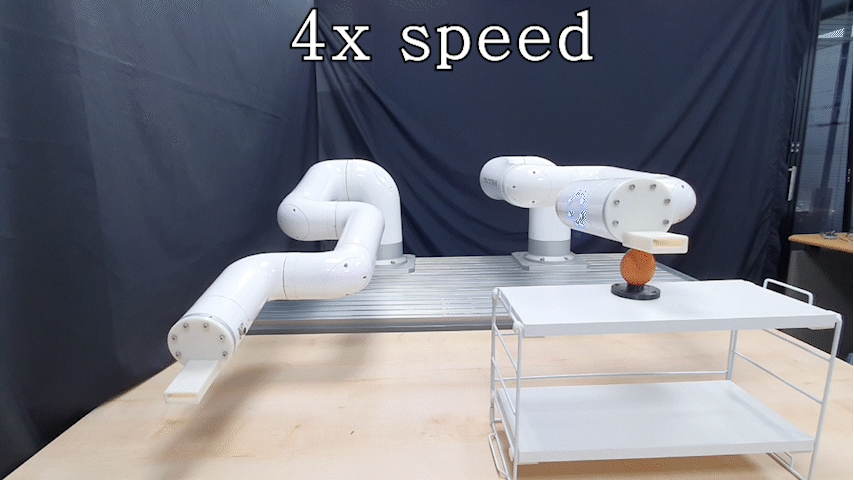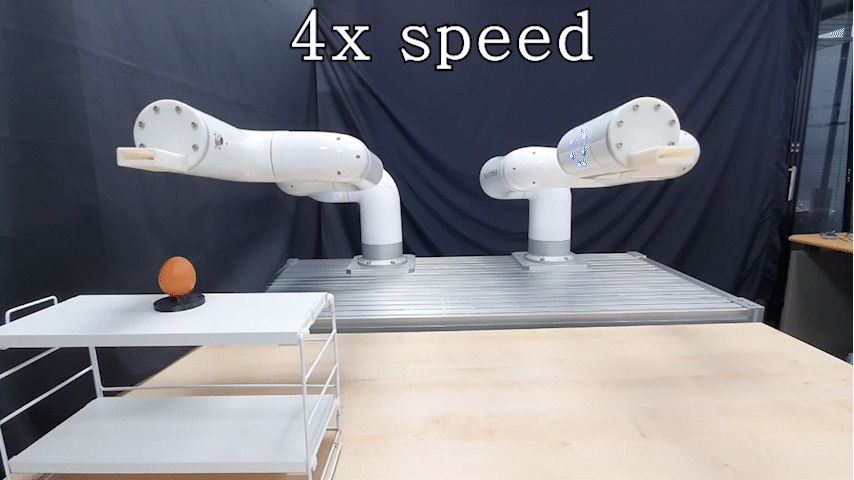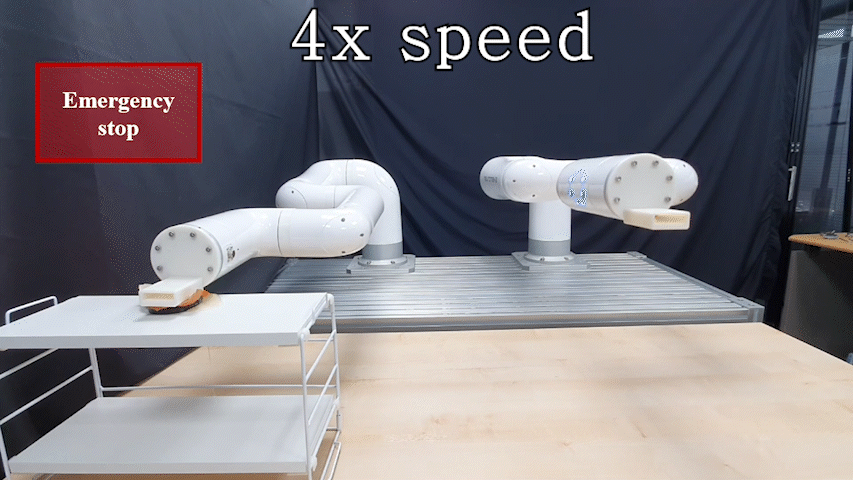
Selected research presented through papers, experiments, and demonstrations.
2026
2025
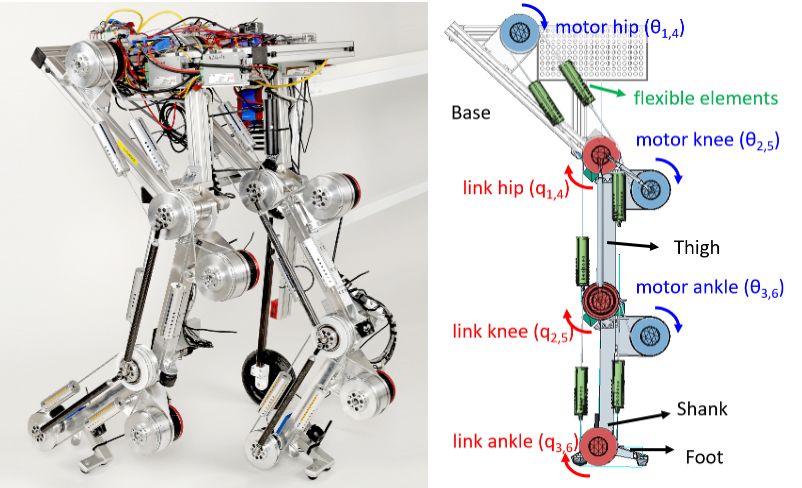
2024
2023
2022
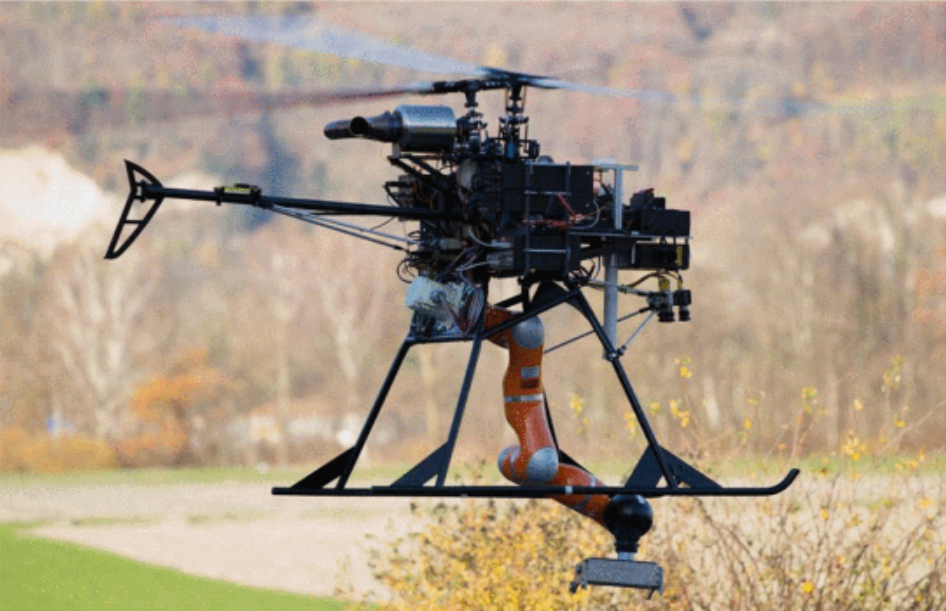
2020
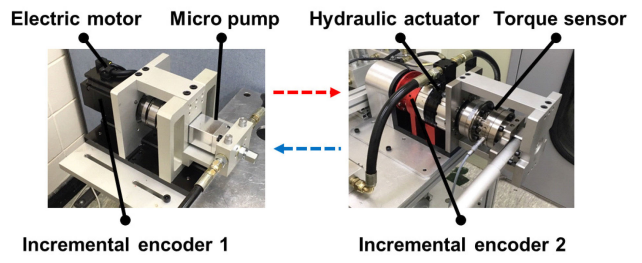
2019
2018
2017
- IROS
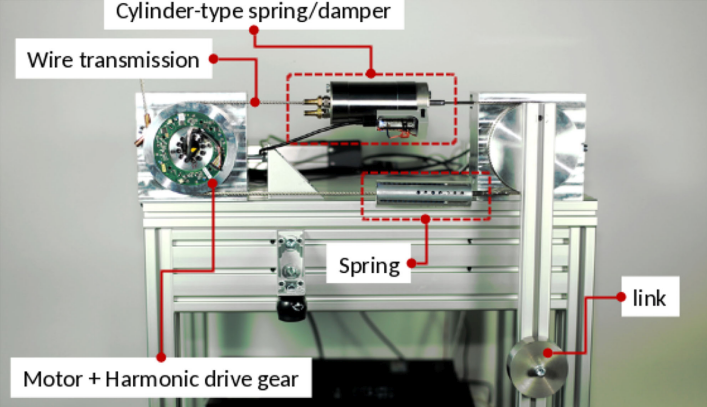
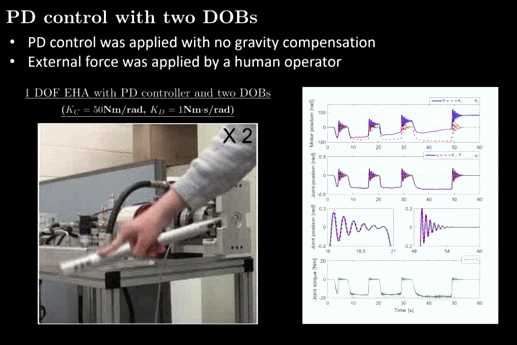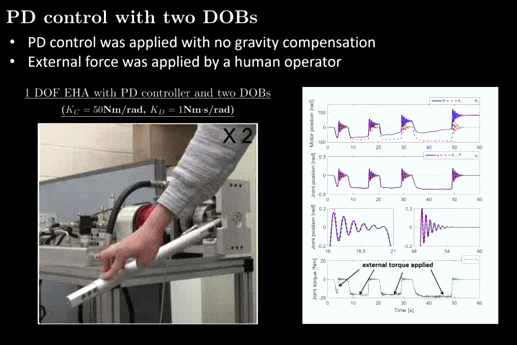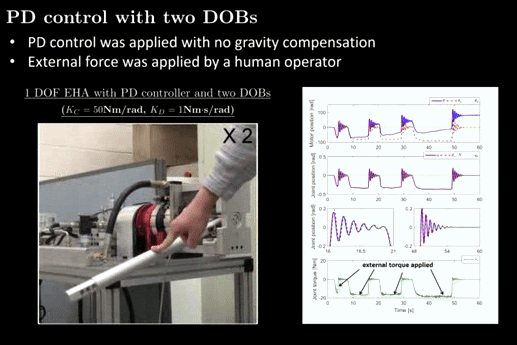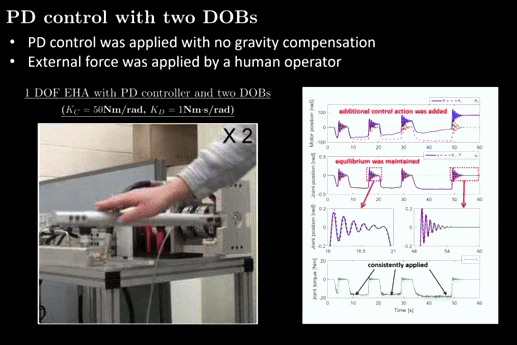 Disturbance-observer-based PD control of electro-hydrostatically actuated flexible joint robotsIEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2017